Four wheels that can change the rover's posture
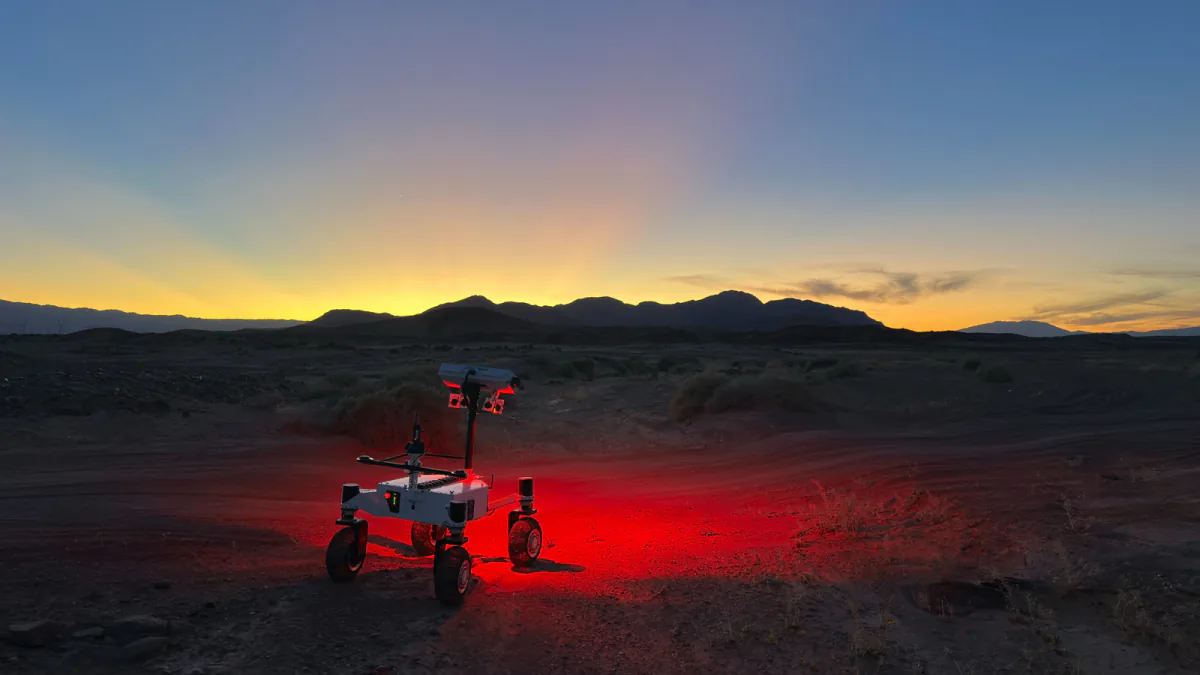
ERNEST—short for Exploration Rover for Navigating Extreme Sloped Terrain—is a roughly 1.2-metre prototype with four steerable mesh wheels. Each wheel can be lifted, and two powered joints in the front gimbal let the rover shift weight and use movements such as wheel-walking, squirming and obstacle climbing.
A clutch lets the vehicle switch between active suspension and a passive mode that JPL describes as less capable on difficult terrain but more energy efficient. That trade-off is important: mobility is not free, and the public release does not quantify energy use across the two modes.
Training begins in a digital terrain
JPL used reinforcement learning in a high-fidelity simulator built from measurements of the real rover's hardware and terrain response. The team ran many simulations in parallel and says it could compress thousands of simulated test hours into a weekend.
After virtual training, the algorithms were tested in JPL's Mars Yard over sand ripples, rubble, steps and slopes. NASA says the rover completed multiple courses, but the release does not provide the training dataset, model architecture, intervention rate or a controlled comparison with alternative controllers.
Twenty-six kilometres in the Colorado Desert
During seven days in March 2026, ERNEST covered about 16 miles, or 26 kilometres, across 37 hours of drive time near Plaster City, California. JPL reports speeds up to 0.6 mph, or about 1 km/h, with minimal intervention.
The team also operated at dawn, dusk and night to explore lighting conditions relevant to large shadows near the Moon's poles. A terrestrial campaign can reveal endurance and autonomy problems; it cannot reproduce lunar gravity, vacuum, radiation, dust or temperature cycles.
The stated next step is integration
JPL's stated next objective is to combine decisions about when and how to use active suspension with longer-range navigation. The rover would then weigh whether to cross a manageable obstacle or route around a hazard.
The capability could inform future missions, but ERNEST is a research prototype and NASA/JPL's release does not announce a Moon or Mars flight assignment. The documentary photograph records the field test, not readiness for spaceflight.
The experiment is a ladder, not one completed capability
| Stage | What the reported work supports | What it does not establish |
|---|---|---|
| Simulation | Learned control policies can be trained against a model of hardware and terrain. | That every real surface, mechanical fault or lighting condition was represented. |
| JPL Mars Yard | The trained approach can be exercised on selected physical obstacles. | A quantified win over every alternative controller or on arbitrary terrain. |
| March 2026 desert campaign | Longer navigation operations on Earth: about 26km over 37 driving hours across seven days. | That the complete learned-suspension and long-range system was already integrated. |
| Future integration | A proposed system deciding whether to negotiate an obstacle or route around it. | An already delivered Moon or Mars mission capability. |
A simulation makes repeated experimentation affordable and lets researchers expose a policy to many conditions. It also encodes assumptions. Testing on the real rover asks whether those assumptions survive contact with wheel slip, sensors and hardware. A longer field campaign then asks a different question: can navigation remain useful when the vehicle must keep operating beyond one obstacle course?
The essential comparison is therefore not “AI versus humans” in the abstract. It is a specified controller, on a defined terrain set, against an identified alternative, with interventions, energy use and failed attempts recorded. The public release does not provide that controlled comparison. Dividing distance by driving time would only give an aggregate of this campaign, not prove a controller’s speed advantage.
The related NASA ASTRA robot-fleet research addresses coordination across robots. ERNEST addresses a different mobility problem. They can inform a broader account of autonomy without sharing a scorecard, being the same project or demonstrating each other’s results.
Sources & Methods
Published reporting and original source context are retained. September 23 revision: Added an evidence-stage comparison distinguishing simulation, Mars Yard tests, the March desert campaign and future integration. New explanatory examples are explicitly hypothetical; no independent hardware or model benchmark is claimed.
- JPL — NASA Testing Advanced Capabilities for Moon, Mars Rovers — primary source
- NASA Photojournal — Desert Field Test With NASA Advanced Rover Prototype — primary image source
- JPL — Image Use Policy — image rights source
- NASA — Images and Media Usage Guidelines — image rights source