Two drives planned with vision-language models
Perseverance executed the routes on December 8 and 10, 2025, during mission sols 1707 and 1709. NASA describes them as the first drives on another world planned by artificial intelligence. The rover travelled 210 metres on the first route and 246 metres on the second.
The system analysed high-resolution HiRISE orbital imagery and digital elevation models, identifying features such as bedrock, outcrops, boulder fields and sand ripples before generating a continuous route with waypoints. JPL worked with Anthropic and used Claude models, but the release does not identify the exact version or prompts.
Human oversight remained part of the command chain
The generated plan did not travel directly from a chatbot to Mars. JPL engineers processed the drive commands through a digital twin of Perseverance and checked more than 500,000 telemetry variables for compatibility with the rover's flight software before uplink.
That distinction matters. The demonstration inserted generative AI into ground-based route planning while engineers checked flight-software compatibility and the rover retained its existing onboard navigation safeguards; it did not establish a free-running generative agent in control of the vehicle.
The operational promise is distance and workload
Mars is too far away for real-time joystick control. Human planners traditionally study terrain and status data, place waypoints—typically no more than 100 metres apart—and send a command plan through the Deep Space Network.
JPL's longer-term goal is to use generative AI and other tools for kilometre-scale drives while reducing operator workload. Two successful routes show feasibility, not a measured productivity gain across different terrain, seasons or rover states.
What the route image shows
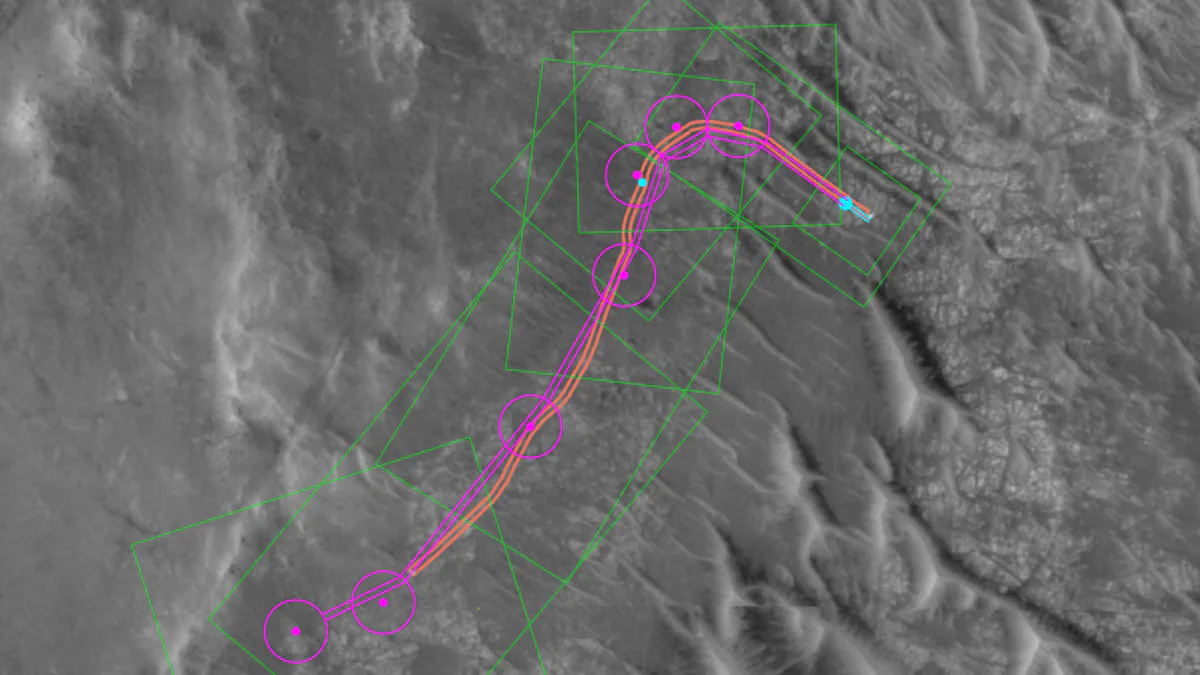
The documentary hero is NASA's annotated PIA26645 orbital image of the exact sol 1709 demonstration. It shows the AI-planned wheel path and waypoints in magenta, the route reconstructed from downlinked rover data in orange, and the mission team's keep-in zones in green.
The image directly documents the planned and executed routes, but it does not establish that AI planning was safer or more efficient than human planning. Those performance questions remain outside the two-drive demonstration.
Where the AI plan ends and the rover’s autonomy begins
- Observe and propose on Earth. Orbital imagery and elevation information are inputs to a ground-planning task. The generated route is a proposal, not an instruction already executing on Mars.
- Review and validate. Engineers process the proposed drive commands through the rover’s digital twin and flight-software compatibility checks before approving an uplink.
- Transmit and execute. The authorised command sequence goes through the Deep Space Network. Onboard navigation deals with the nearby terrain during the drive; returned telemetry lets the team compare plan and execution.
AutoNav was not invented by this demonstration. JPL described Perseverance’s onboard system in 2021: it constructs three-dimensional terrain maps, recognises hazards and finds routes around obstacles without requesting a new Earth instruction for each adjustment. That local navigation role is distinct from using a vision-language model to help prepare a route on the ground.
Think of it as two decisions at different scales. Ground planning chooses a scientifically useful path under mission constraints. Onboard autonomy reacts to terrain the vehicle can currently observe. Neither role eliminates the need to know the rover’s condition or to define where it is allowed to go. A convincing plan from orbital imagery cannot by itself verify that every nearby obstacle is traversable.
The next useful evidence would compare accepted plans, rejected commands, operator review time and actual progress on matched tasks. It would retain failures, not only two completed drives. Until that evidence exists, “AI-planned” accurately identifies part of the workflow; “fully autonomous generative AI mission” would not.
Sources & Methods
Published reporting and original source context are retained. September 23 revision: Added a ground-to-rover command chain and a comparison with pre-existing AutoNav. No speed or safety improvement is inferred. New explanatory examples are explicitly hypothetical; no independent hardware or model benchmark is claimed.
- JPL — Perseverance completes first AI-planned drive on Mars — primary source
- NASA Photojournal — Mapping Perseverance's Route With AI — primary image source
- NASA — Images and Media Usage Guidelines — image rights source
- JPL — Perseverance AutoNav background — Primary documentation, checked September 23, 2026